Human Instability
HydroPol2D includes an implemented human-instability module that uses routed surface depth and velocity to estimate pedestrian hazard. The current public theory should distinguish clearly between the implemented modes:
| Mode | Current state | Description |
|---|---|---|
1 | Implemented | Continuous force-balance risk ratio based on buoyancy, available friction, and hydrodynamic drag. |
2 | Not implemented | Placeholder only. Do not document or use as an active public option. |
3 | Implemented | Geometry-based instability classifier with slide, topple, and drowning/drawing thresholds. |
The current validation status for these modes is tracked in the validation status.
1. Inputs and Coupling
The human-instability module reads the hydrodynamic state from HydroPol2D:
- routed surface depth ,
- routed velocity magnitude ,
- local slope when the geometry-based classifier is used,
- and user-supplied human geometry and resistance parameters.
This means the instability estimates are diagnostic products of the coupled hydrologic-hydrodynamic simulation rather than a standalone hydraulic solver.
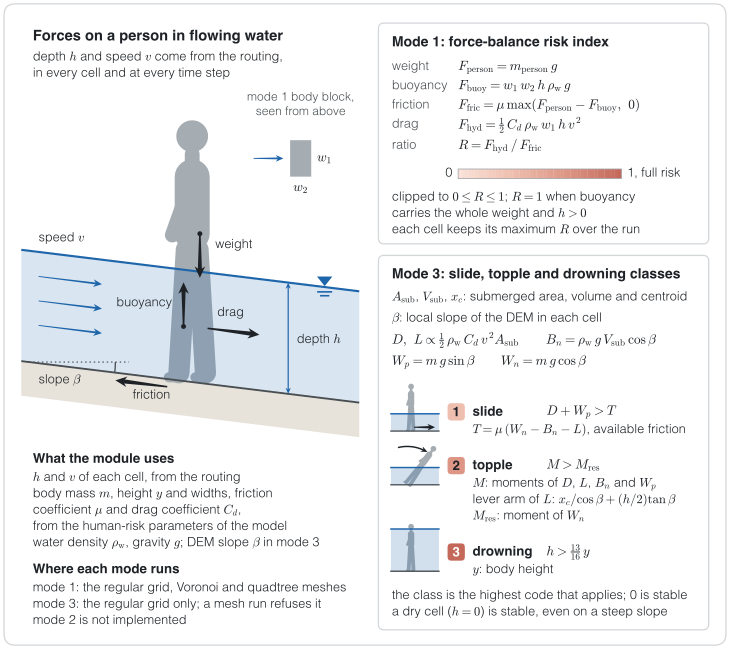
Figure 1. The forces on a person in flowing water and the two implemented modes. Mode 1 gives a risk index from 0 to 1, and mode 3 gives a class (stable, slide, topple or drowning) on the regular grid only.
2. Mode 1: Force-Balance Risk Ratio
Mode 1 represents instability as a competition between hydrodynamic forcing and the frictional support that remains after buoyancy reduces body weight.
2.1 Weight and buoyancy
The body weight force is
The buoyancy force is approximated as
where:
- is body mass
- is gravitational acceleration
- and are characteristic body widths
- is water depth
- is water density
2.2 Available friction
The friction available to resist motion is
where is the effective ground-contact friction coefficient.
2.3 Hydrodynamic force
The hydrodynamic loading is represented as
where:
- is drag coefficient
- is routed velocity magnitude
2.4 Risk ratio
The force-balance risk ratio is then
for supported states where . In the current implementation:
- cells with no remaining support but positive water depth are assigned full risk,
- the final risk value is clipped to the range ,
- and a running maximum-risk map can be accumulated over the simulation.
Mode 1 therefore returns a continuous hazard indicator rather than a categorical failure mode.
3. Mode 3: Geometry-Based Instability Classifier
Mode 3 uses person geometry, flow depth, flow velocity, and ground slope to classify the dominant failure mechanism.
3.1 Submerged geometry and forces
The code computes submerged area, submerged volume, and the submerged centroid as a function of water depth relative to body dimensions. Those geometric quantities are then used to estimate:
- drag and lift-like hydrodynamic loading,
- downslope and normal components of body weight,
- buoyancy,
- and the lever arms needed for overturning.
Conceptually, the main force terms are:
where:
- is submerged projected area
- is submerged volume
- is local slope angle
3.2 Sliding threshold
Available resisting friction is approximated as
where is the lift-like hydrodynamic contribution. Sliding is classified when the driving force exceeds the available friction:
In the output map, slide corresponds to code 1.
3.3 Toppling threshold
The module also computes an overturning moment from the drag , the lift , the buoyancy and the downslope weight component , each with a lever arm set by the body geometry, the submerged centroid and the slope. The resisting moment comes from the normal weight component . Toppling is classified when the driving moment exceeds the resisting moment:
In the output map, topple corresponds to code 2.
3.4 Drowning/drawing threshold
The implementation also applies a depth-based drowning/drawing threshold:
where is the characteristic body height used by the geometry routine. In the output map, this failure mode corresponds to code 3.
3.5 Final categorical map
The final mode-3 hazard class is the maximum of the slide, topple, and drowning/drawing indicators:
This produces a categorical instability raster rather than the continuous ratio returned by mode 1.
A dry cell () is stable (code 0), as in mode 1: with no water there is no one in the flow to classify. Without this rule, the person's own weight would make every dry cell steeper than (31° for ) a slide.
4. Scope and Documentation Notes
The current public story for human instability should stay aligned with the code:
- mode
1is implemented and documented as a force-balance ratio, - mode
3is implemented and documented as a geometry-based classifier, - mode
2is not implemented, - validation claims should remain tied to the controlled evidence summarized on the validation status,
- and the human-instability module should be described as a coupled hazard diagnostic driven by HydroPol2D depths and velocities.